
- Electric Motor
- Separate Gearbox
- Motor Driver / Electronics
- Mechanical Assembly & Sensors
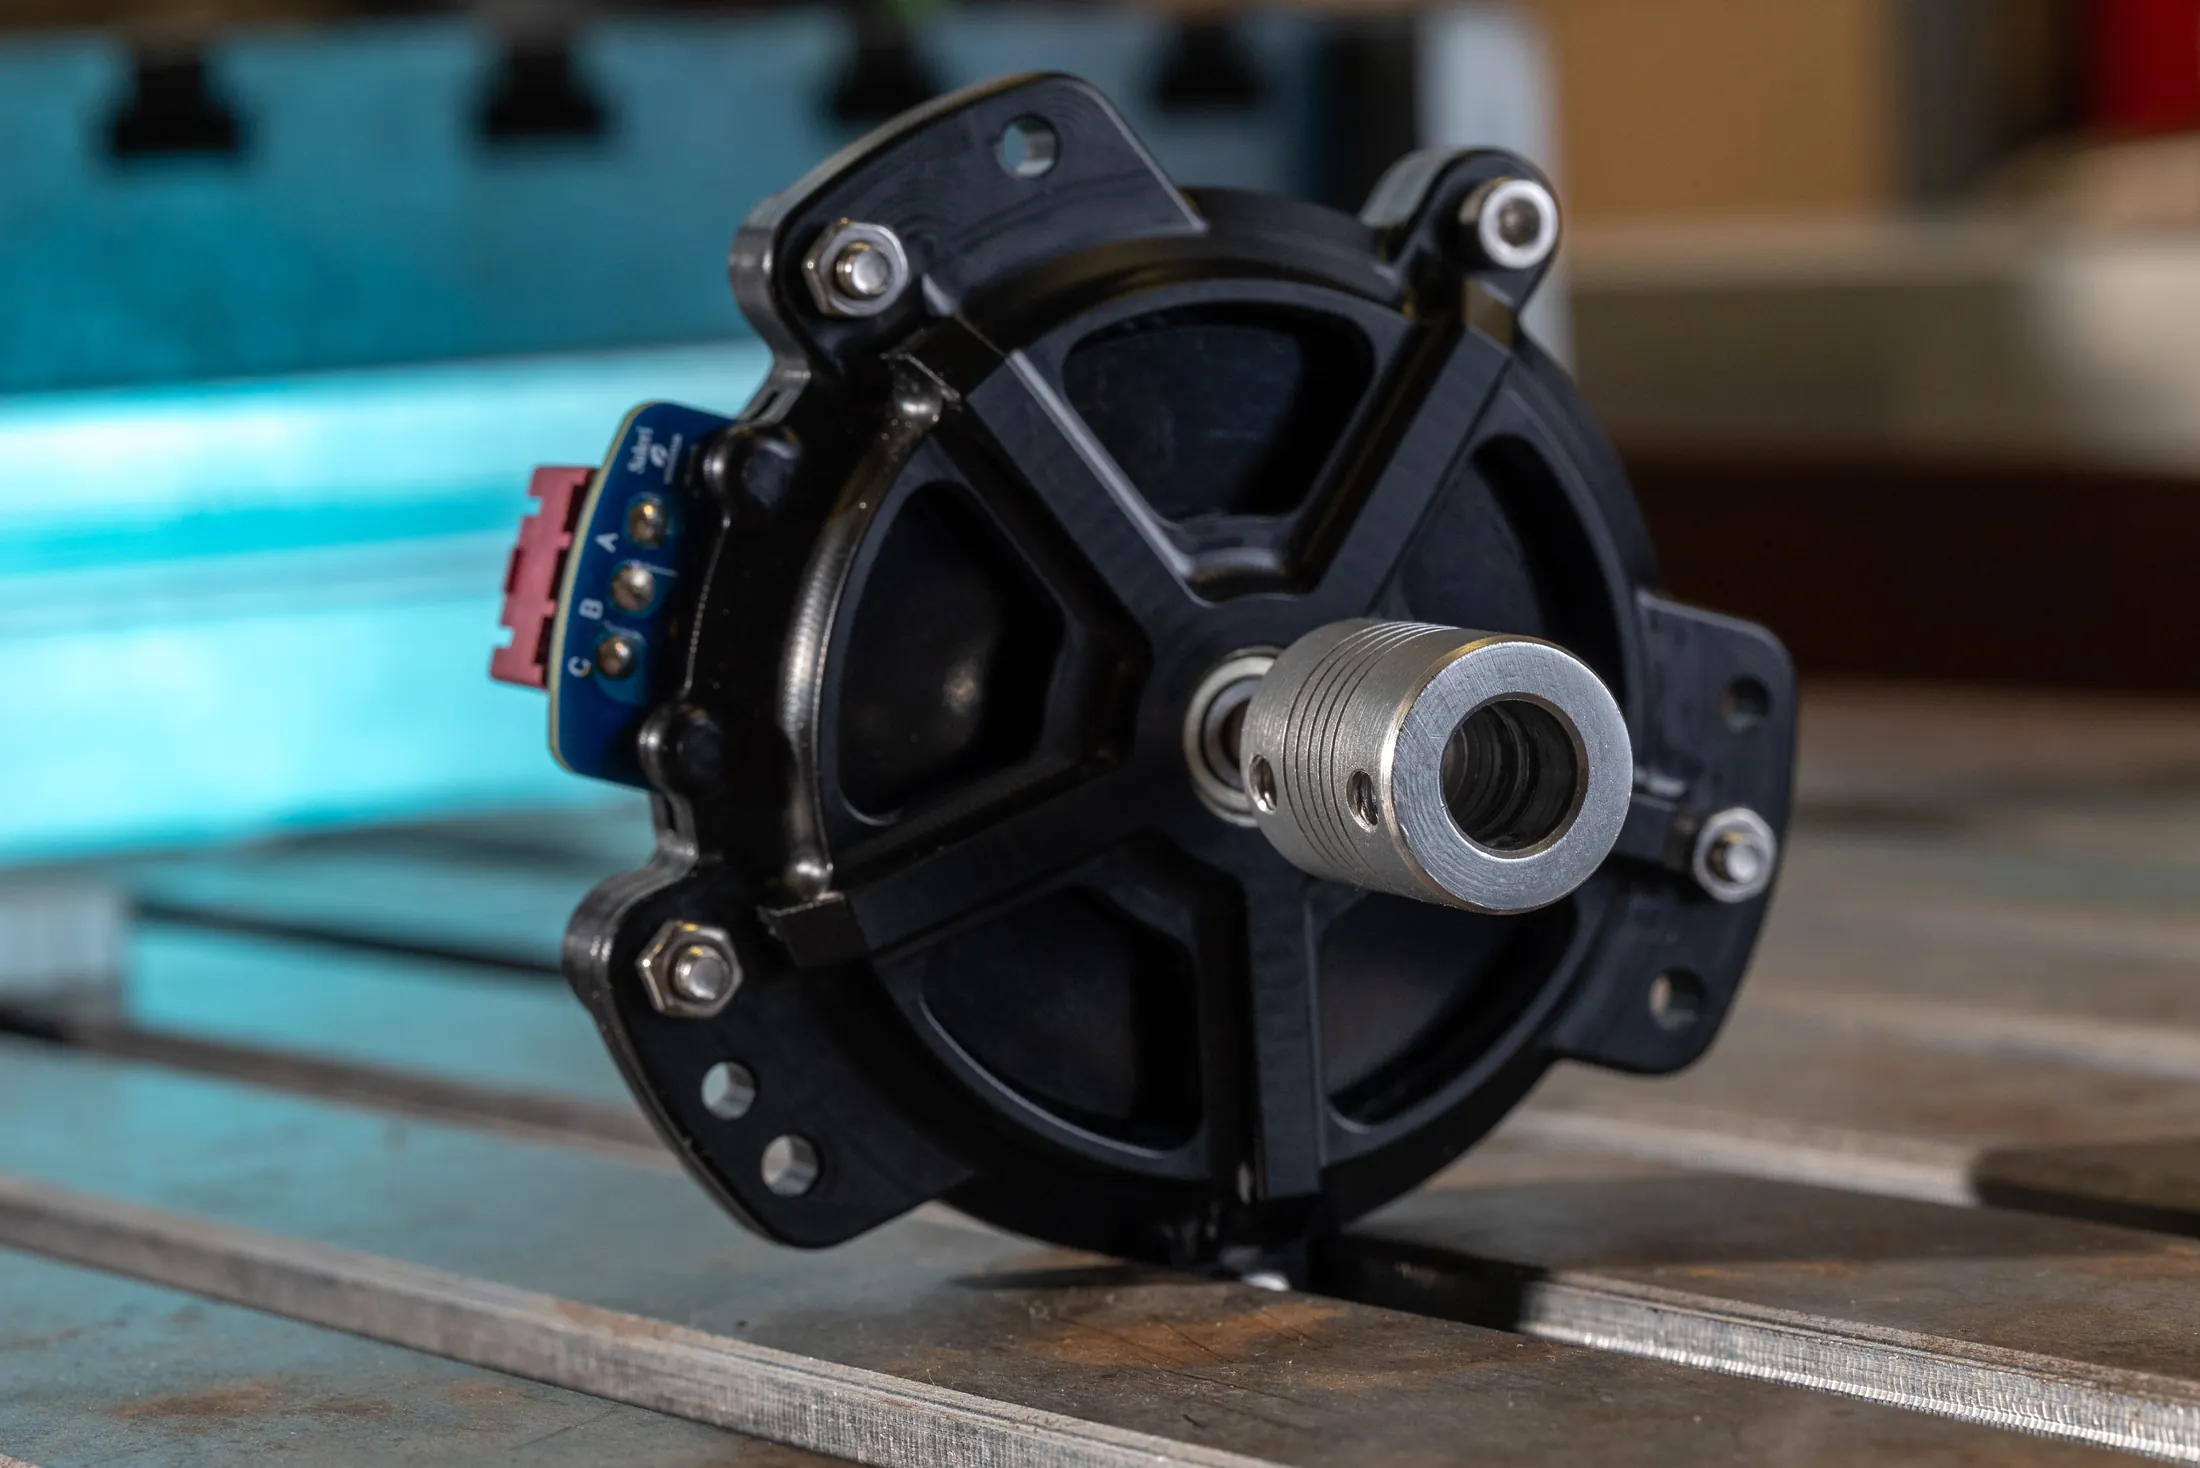
More Than a Motor.
NOVAMOT prints the stator winding, the drive electronics and the position sensors into one multi-layer PCB — geared or direct-drive. Without hand-wound copper or bolted-on assembly.
The Idea
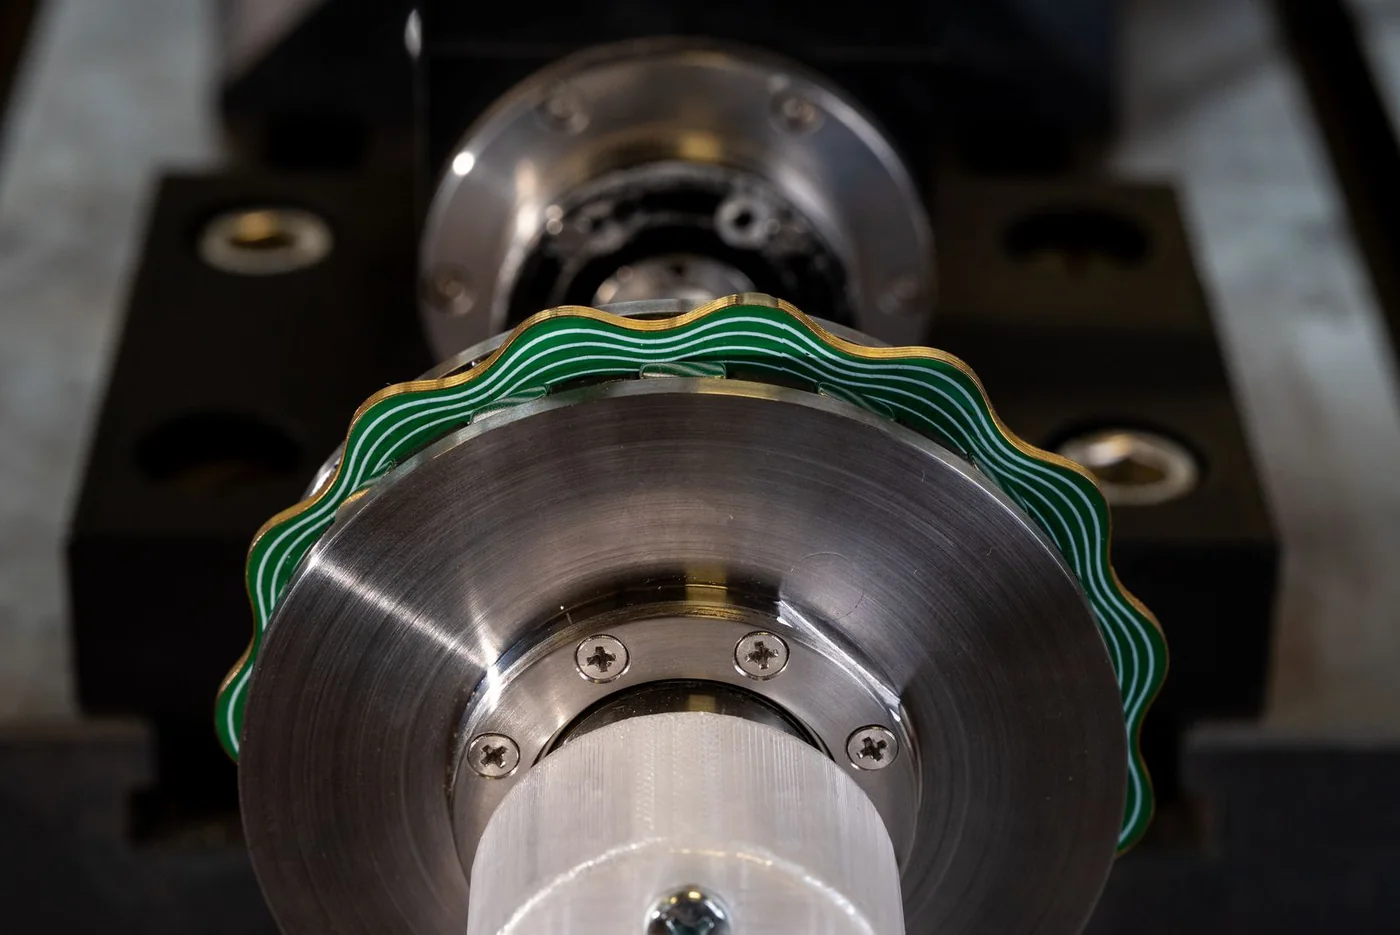
Four functions integrated into one board
Actuators are the largest single cost item in a humanoid robot — up to 60% of the bill of materials — and inside each one the gearbox usually costs more than everything else combined. Improving the motor or the gearbox on its own does not change that; the limit is how the actuator is built. NOVAMOT's design tools and patents enable a single printed board to perform functions that currently require four separate parts.
Single-board integrationNo separate drive, gearbox, position sensor or connectors
Reduced mass and axial lengthApproximately 30% lower mass and axial length compared with a complete motor-plus-gearbox actuator.
Reduced manufacturing costs40–50% lower joint manufacturing cost — standard PCB suppliers, no winding tooling.
Side by side
Conventional architecture
NOVAMOT architecture
Conventional stack vs. NOVAMOT
- Stator & gearOne board
- Driver & sensorsSame board
- Structure & fixtureThe board itself
- ConnectorsPrinted traces
Operating principles
01
02
03
Coreless axial-flux motors for precision motion
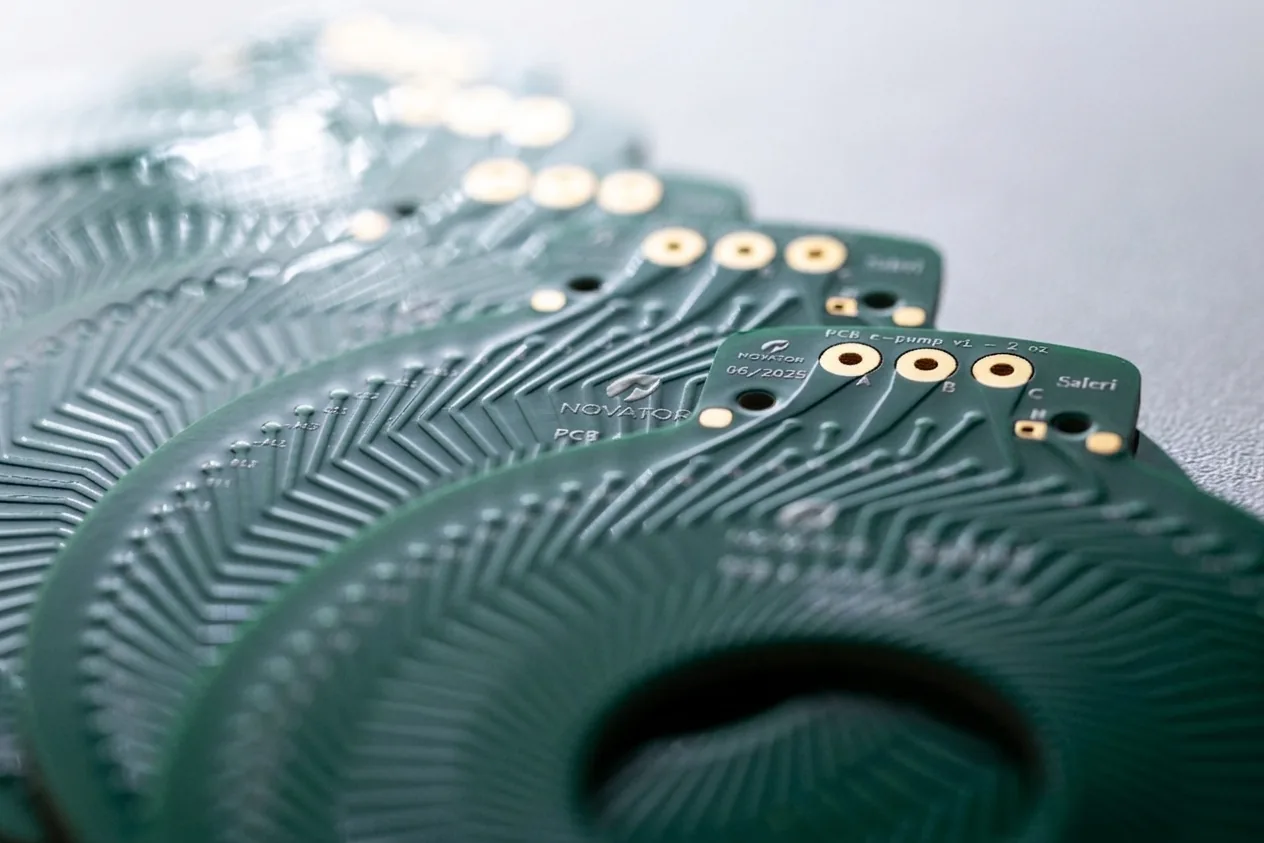
A PCB motor is an axial-flux machine whose stator winding is printed as copper traces on a circuit board — no hand-wound wire, no iron core. Removing the core gives it exactly the properties precision robotics, gimbals and drones depend on.
The winding is printed copper on a circuit board. No hand-wound wire, and no iron core for the magnets to cog against.
Zero cogging torque
No detent steps or torque ripple — smooth, sub-degree positioning and pointing, ideal for gimbals and precision actuators.
Low phase inductance
Current rises and settles fast, enabling high control bandwidth and rapid response — paired with GaN drives switching at MHz.
Axially stackable
Stack rotors and stators on one shaft to add redundancy or scale torque — without redesigning the machine.
Products
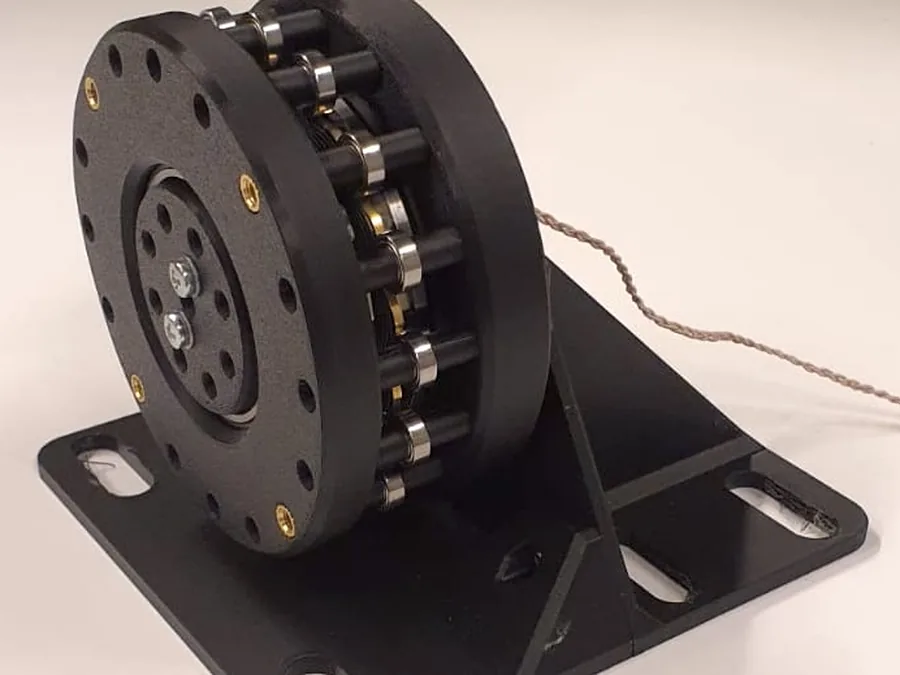 Working prototype
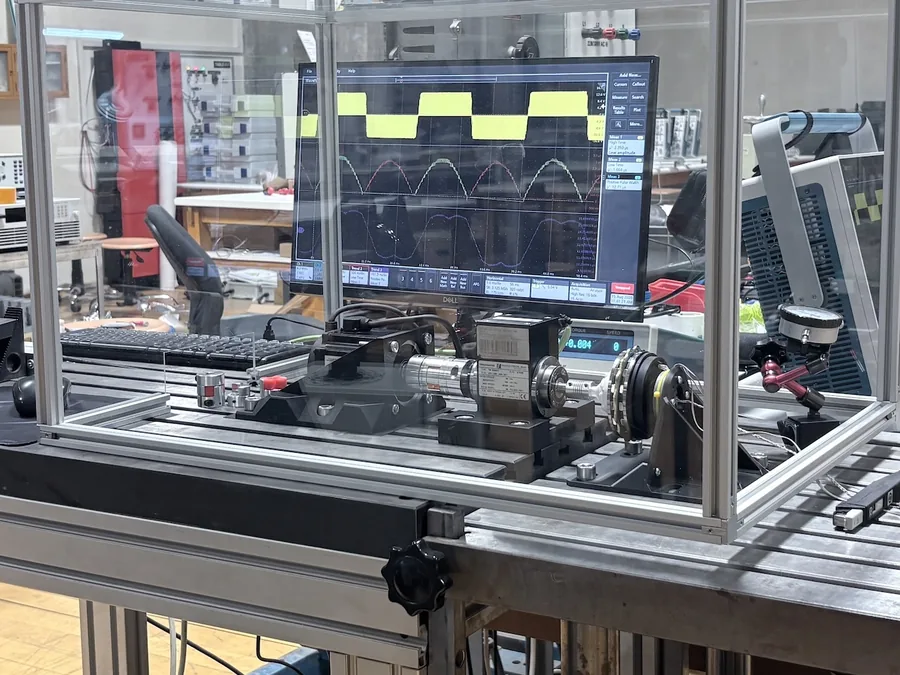 Bench-tested
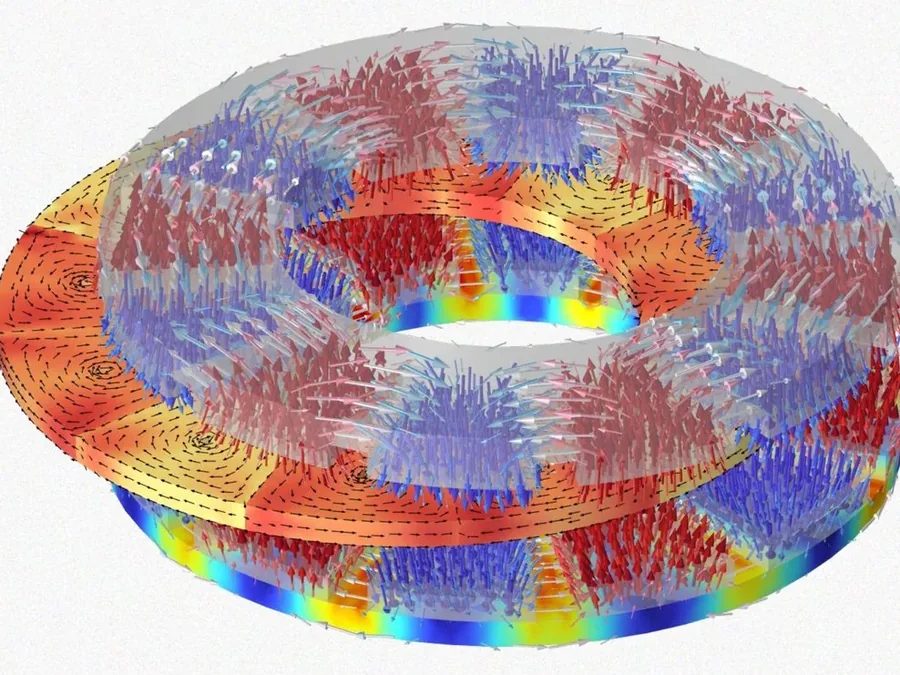 Designed to order
Designed around your application requirements
Because the machine is defined in a design file rather than a winding line, torque, speed, thickness and cost are tuned to the application instead of chosen from a catalogue — and a new variant costs a redesign, not new tooling. That is what lets one platform cover compact robotic joints, gimbals and propulsion.
Working prototypeIntegrated-gearbox actuator
The PCB is the motor stator & the cycloidal gear. No separate gearbox — increased torque density with reduced cost and size.
Bench-testedTest results compared with model predictions
Torque, speed, efficiency and thermal behaviour measured on an instrumented dynamometer, then checked against what the design tools predicted.
Designed to orderOptimised for your application requirements
Electromagnetic, thermal and structural models run in-house, so torque, speed, thickness and cost are set by your envelope — geared or direct-drive.
From the gearless e-pump motor we designed and delivered with Saleri — the same printed stator, without a reduction stage:
150 Wautomotive coolant pump at 12 V, 59 °C passive cooling
6000 rpmdirect-drive — no gearbox, no hand-wound stator
87 %stator cost reduction from 5 to 1000 units
Share your torque, speed and envelope requirements. We will assess feasibility and design the machine to meet them.
Team & Origin
 Co-founder & CTO
 Co-founder & CEO
The research team behind NOVAMOT
NOVAMOT was co-founded by two METU professors. The technology is rooted in METU PowerLab's decade of work on electric machines and power electronics, published in the peer-reviewed literature and protected by a national patent application and a PCT filing.
Co-founder & CTOAssoc. Prof. Ozan Keysan
METU EEE · PhD, University of Edinburgh, on MW-scale air-cored axial-flux permanent-magnet direct-drive generators — the machine family underlying the printed-stator technology. Machines designed by his group at METU are in service: the ANDAR high-precision coreless servo motor, in series production to military and aviation standards; ASELSAN’s 4.3 MW turbine generator, Türkiye’s first domestic MW-scale machine of its kind; and a 44 MVA hydro generator for EÜAŞ. Research areas include electric machines, PCB motors and GaN drives.
Co-founder & CEOProf. Murat Göl
METU EEE · PhD, Northeastern University, on incorporating phasor measurement units into power-system state estimation. His research covers state estimation, smart grids, fault location, power quality and renewable energy integration. At Novator EVG he leads the company and its grid and energy-software work.
Partner with NOVAMOT
We work with OEMs designing around tight enclosures, and with partners and investors supporting the development of NOVAMOT.
keysan@novator.energy